Innovation Platform for Robotics Research & Education
Serving university robotics programs, research institutes, and AI labs, we provide open-interface, open-source SDK, ROS-supported smart end-effector platforms for dexterous manipulation, reinforcement learning, and grasping algorithm research, fostering robotics talent and innovation.
Challenges in Research & Education
Closed Systems
Industrial grippers are usually closed and locked down, with no access to low-level data — unsuitable for research algorithm validation.
Difficult Development
Without mature SDKs and documentation, students struggle to get started, lengthening research cycles.
Poor ROS Support
Many industrial products lack ROS support, requiring custom driver development that wastes research time.
Dexterous Manipulation Difficulty
Traditional grippers have too few degrees of freedom for human-level dexterous manipulation research.
Limited Budgets
Research and teaching budgets are limited, and imported products are expensive to deploy at scale.
Lack of Teaching Resources
Without accompanying teaching cases and lab manuals, instructors struggle to prepare courses.
Core Advantages of Jodell's Research & Education Solutions
Open-Source SDK
A complete SDK supporting C++, Python, C#, and more, with thorough interface documentation.
Full ROS Support
Native ROS1/ROS2 support with URDF models and MoveIt configuration packages — ready out of the box.
Dexterous Manipulation Platform
The Bionic Five-Finger Dexterous Hand offers 12 DoF with integrated force, position, and tactile sensors for dexterous manipulation research.
Rich Interfaces
Ethernet, RS485, and IO interfaces with force and position feedback for real-time data access.
Rich Teaching Resources
Teaching cases, lab manuals, and sample code lower the barrier to classroom adoption.
Great Value
More cost-effective than imported products, ideal for equipping university labs at scale.
Typical Application Areas
Robotics Teaching
Hands-on labs for robotics engineering and intelligent manufacturing curricula.
Dexterous Manipulation Research
Research on dexterous manipulation, hand-eye coordination, and manipulation skill learning with dexterous hands.
Human-Robot Collaboration Labs
Research on human-robot collaboration, safe interaction, and force-controlled assembly.
AI Grasping Research
A platform for training and validating deep-learning and reinforcement-learning grasping algorithms.
Bionic Robotics
End-effector research for bionic hands, prosthetics, and humanoid robots.
Laboratory Automation
Research lab automation, sample handling, and chemistry experiment automation.
Recommended Products for Research & Education
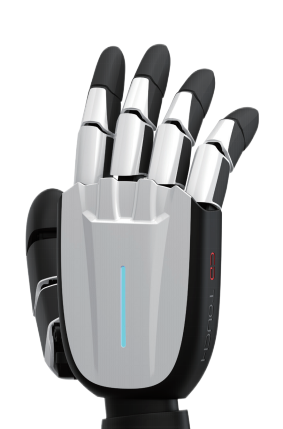
Bionic Five-Finger Dexterous Hand
12 DoF for dexterous manipulation research
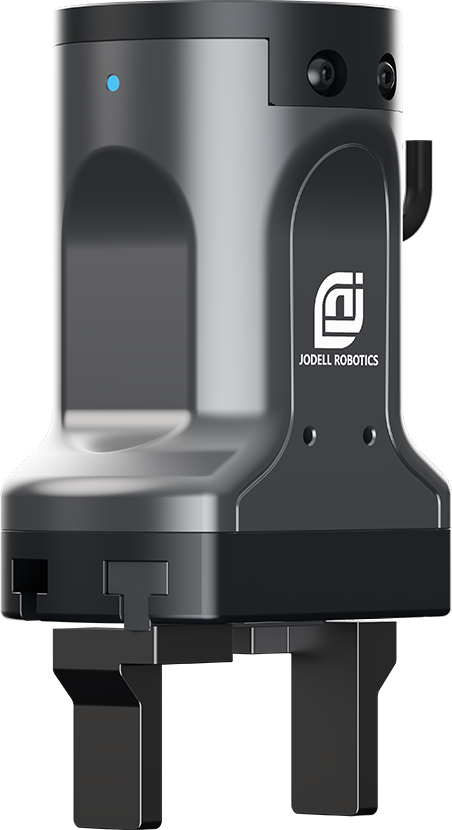
RG Collaborative Robot Gripper
Plug-and-play for teaching labs
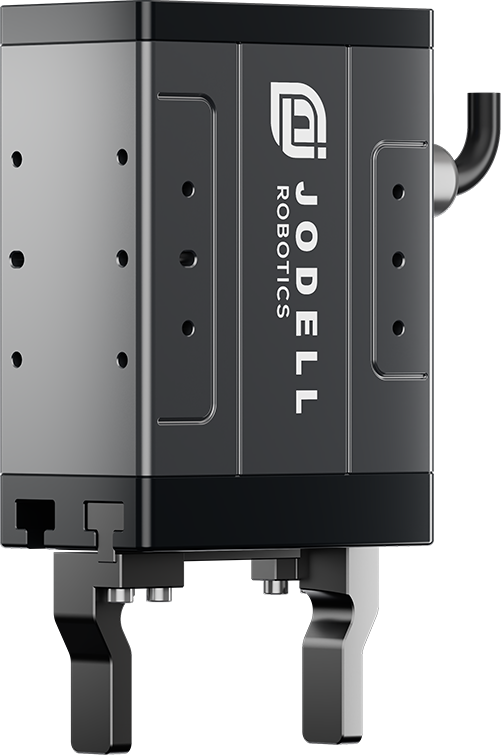
EPG Series Electric Gripper
General gripping for algorithm validation
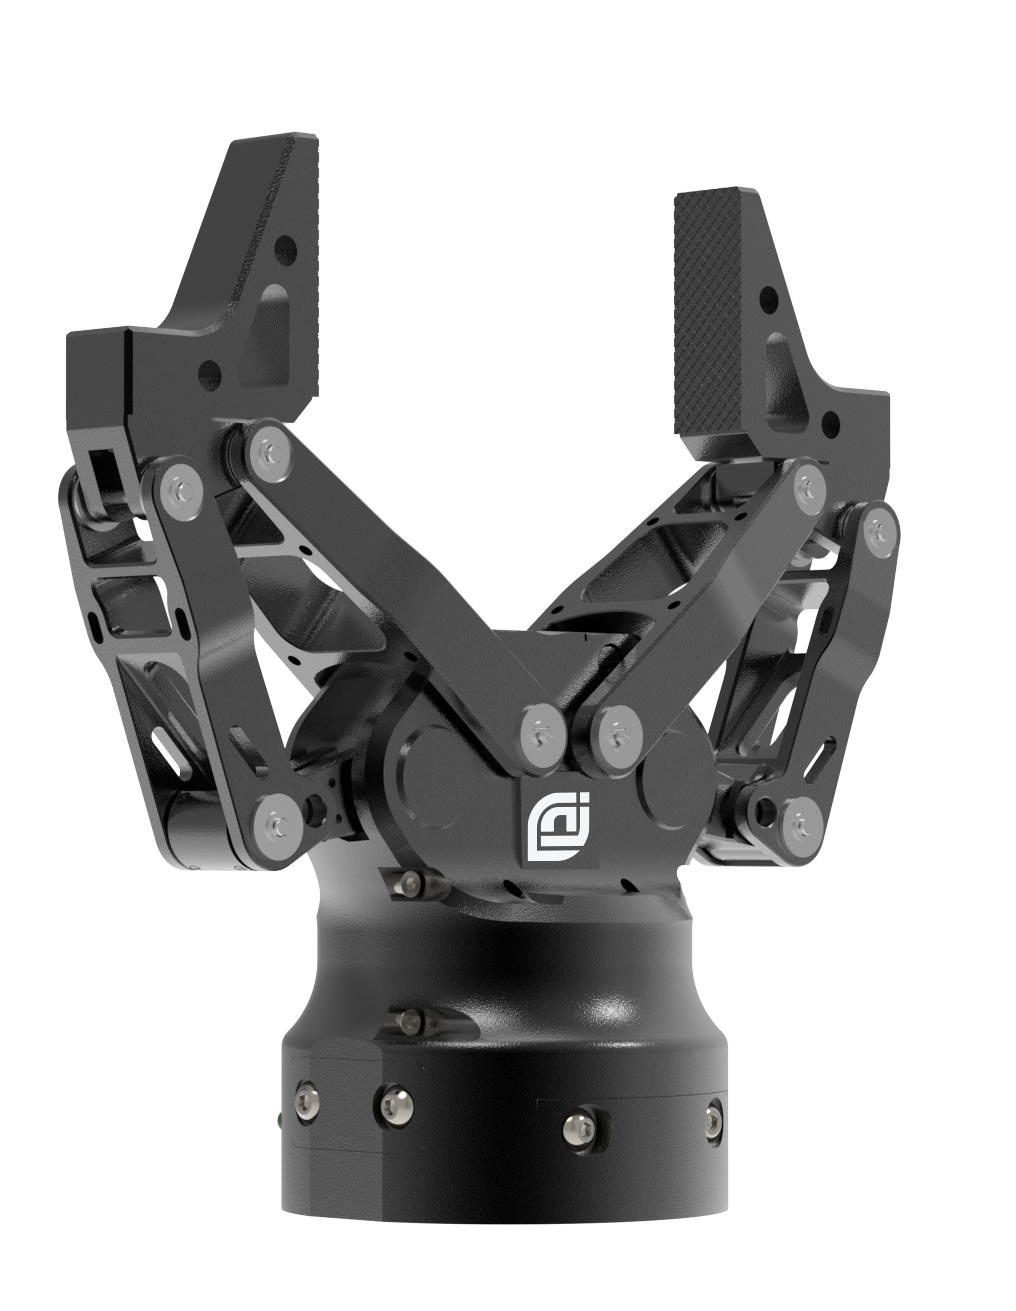
RAG Series Adaptive Gripper
Adaptive gripping for flexible manipulation
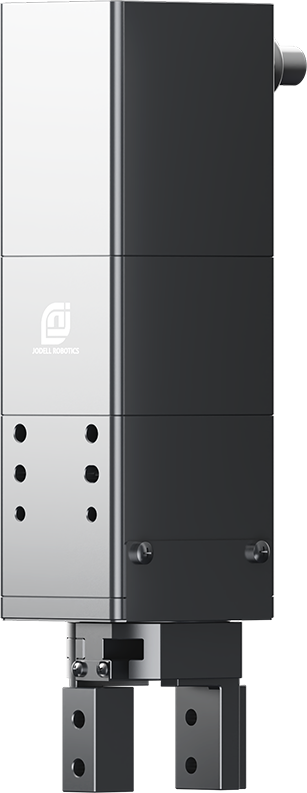
ERG Rotary Gripper
Rotary operation for assembly experiments
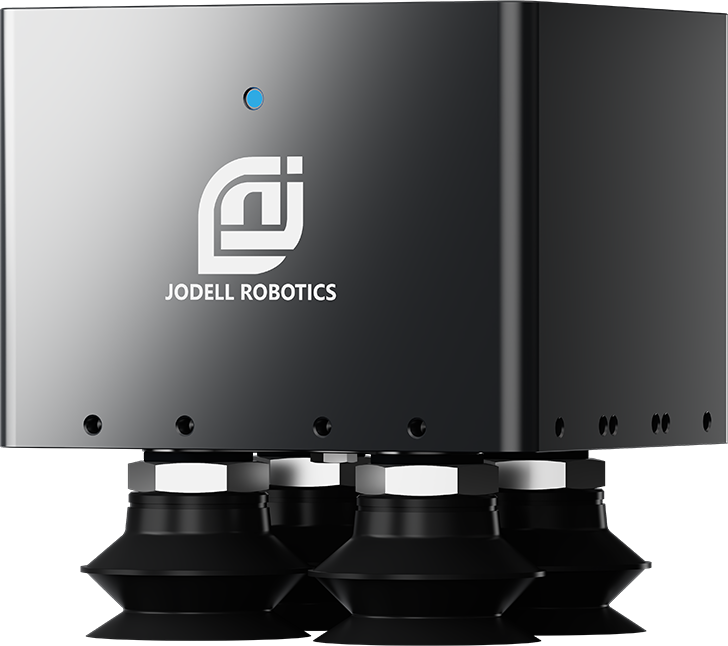
EVS Vacuum Actuator
Vacuum pickup for multi-modal grasping
Value We Deliver
Frequently Asked Questions
What is the difference between the research and industrial versions?
The research version targets universities and research users. Differences: 1) Openness: the research version provides lower-level control interfaces and real-time data access, while the industrial version offers application-layer APIs; 2) SDK: the research SDK is more complete with more sample code and documentation; 3) ROS: native ROS1/ROS2 support with full ROS packages; 4) Pricing: discounted rates for education and research users; 5) Technical Support: dedicated research engineering support for development issues; 6) Teaching resources: teaching cases and lab manuals. The hardware is essentially identical with the same reliability.
Is ROS supported? How do I install it?
The full Jodell product line natively supports ROS1 (Noetic) and ROS2 (Foxy/Humble). Installation: 1) Directly via apt: sudo apt install jodell-ros-driver; 2) Or build from source: git clone the repo into catkin_ws/src and run catkin_make. Complete URDF models, MoveIt configuration packages, and Gazebo simulation models let you visualize and simulate in RViz, developing algorithms without real hardware.
What research can the dexterous hand support?
The Jodell Bionic Five-Finger Dexterous Hand has 12 active DoF with integrated position and force sensors, supporting leading-edge research such as: 1) Dexterous manipulation — grasping objects of various shapes, rotating objects, using tools; 2) Hand-eye coordination — vision-guided fine manipulation; 3) Reinforcement learning — deep-RL manipulation skill learning; 4) Bionic control — emulating human hand control strategies; 5) Teleoperation — master-slave remote control; 6) Prosthetics — smart prosthetic control research. It is already used in research at Tsinghua, HIT, Zhejiang University, and other institutions.
Do you provide teaching solutions?
Yes. Jodell offers complete robotics teaching lab packages: 1) Lab manuals covering 20+ experiments on basic gripper control, force-controlled gripping, vision-guided gripping, and ROS programming; 2) Sample code for Python/C++/ROS; 3) Lecture-ready teaching slides; 4) Integrated lab bench solutions combining robot, vision, and gripper; 5) Instructor training. Multiple universities have built robotics labs with Jodell products.
Can students get started quickly?
Yes. Jodell products are designed for teaching ease: 1) Graphical tuning software controls the gripper without coding to understand parameters; 2) A simple Python API gets gripper initialization, open/close, and force-controlled gripping running in about 10 lines; 3) The ROS driver launches with one launch file to show the model in RViz; 4) Beginner-to-advanced tutorials and videos are provided; 5) Technical support groups answer questions anytime. Undergraduates typically complete basic experiments independently within 1-2 weeks.
Get Your Dedicated Research & Education Solution
Jodell Robotics brings deep research & education experience and delivers customized smart end-effector platforms for your lab.